AI Model Collection Showcase Continues: Meet Ego Lanes!
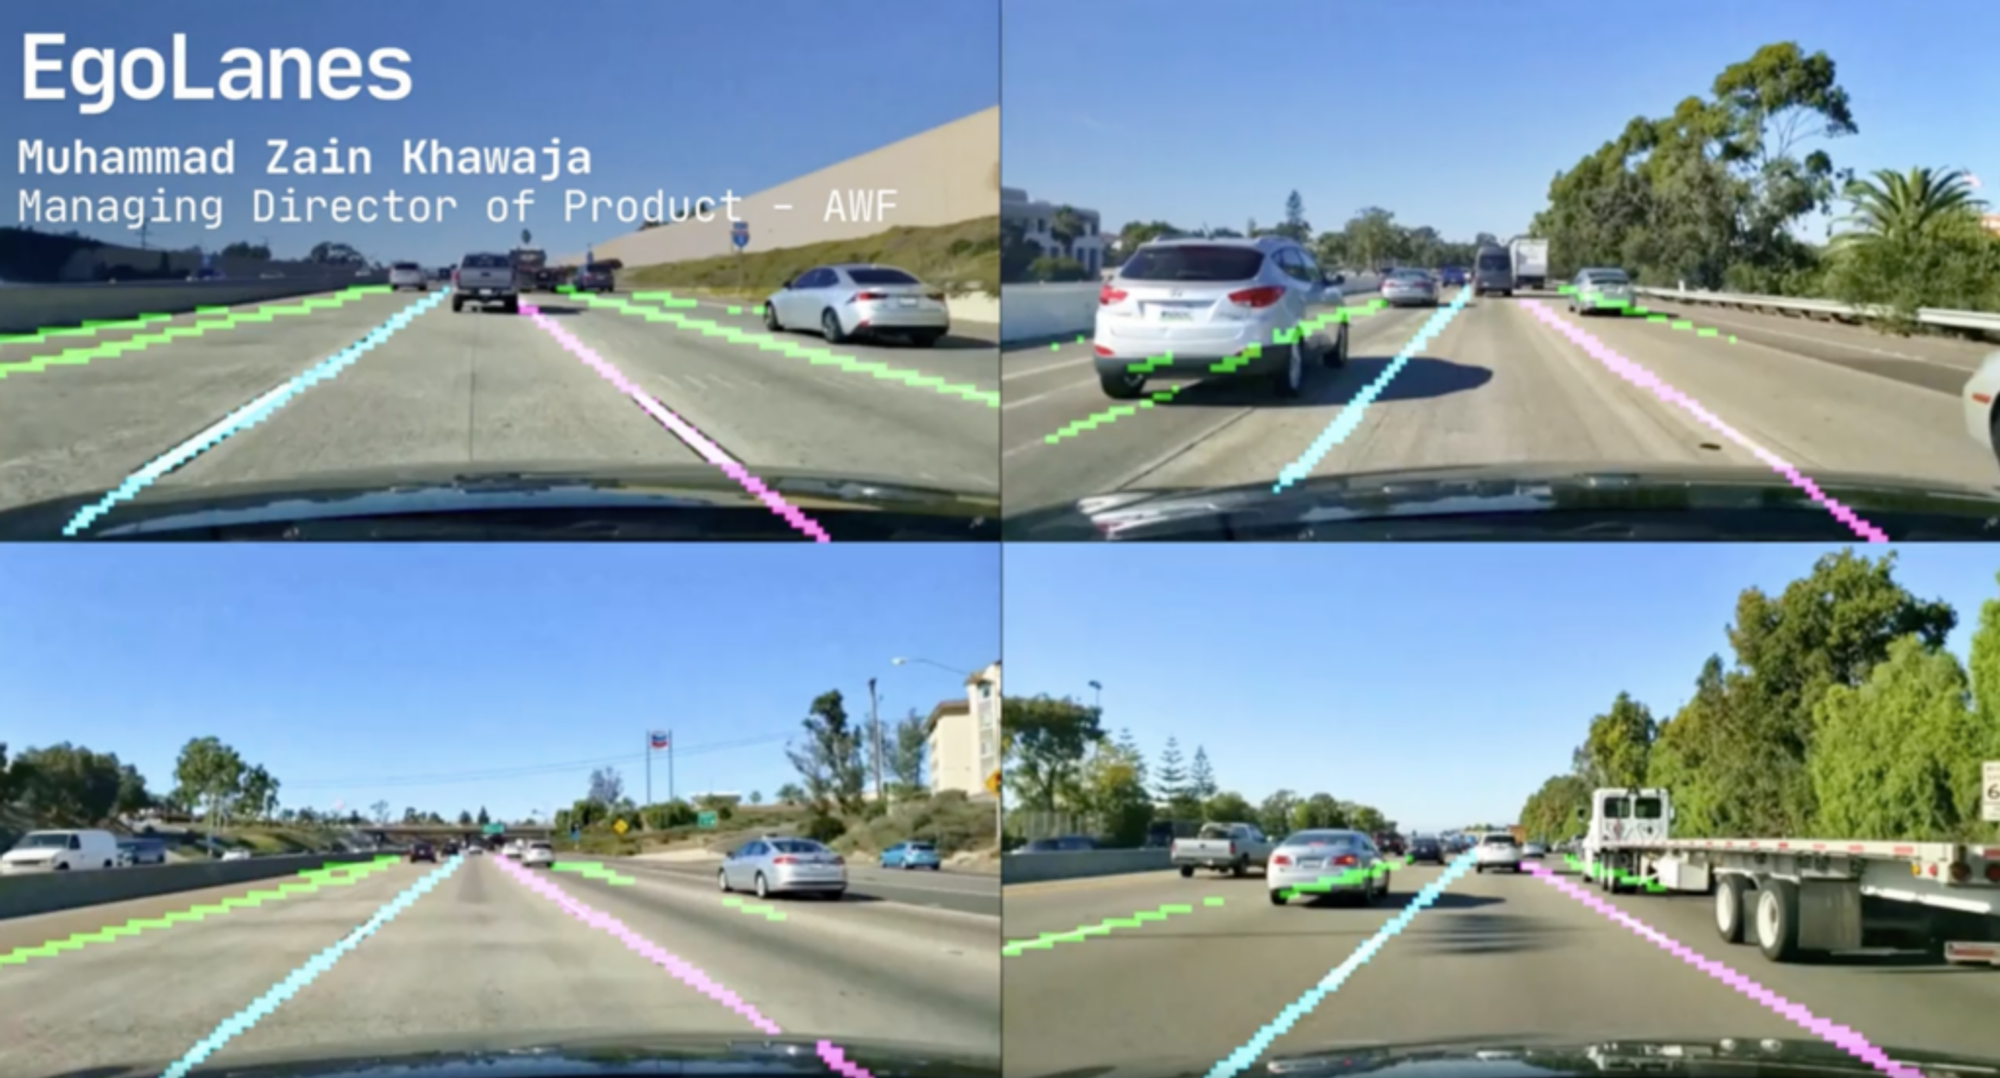
Ego Lanes is an AI-based, open source lane detection system that identifies ego lanes and road edges from a single camera — even at night, in heavy rain and through complex lane changes.
Lane understanding is a foundational capability for safe and reliable automated driving — and it gets especially challenging when conditions are not perfect.
🌙 Nighttime driving 🌧️ Heavy rain and wiper occlusions 🛣️ Complex lane changes and unclear road edges
That is precisely where Ego Lanes comes in.
🚀 Ego Lanes is an AI-based, open source lane detection system that processes raw camera images and identifies: 🟣 The current right ego lane 🔵 The current left ego lane 🟢 All other lane markings and road edges
What makes it stand out?
🧠 Neural-network–based perception directly from raw images 🔄 Dynamically updates lane labels during lane change maneuvers 🌙 Robust performance in low-light and nighttime scenarios 🌧️ Reliable detection under heavy rain, occlusions, and visual noise 📷 Requires only a single front-facing camera ⚡ Runs in real time on low-power embedded hardware
These capabilities unlock core ADAS and autonomy features such as:
- Lane Departure Warning
- Lane Keep Assist
- Hands-Free Driving
Ego Lanes is designed as a production-oriented, open source building block for automotive OEMs and Tier-1 suppliers — developed openly, validated transparently, and improved collaboratively.
🙏 A big thank-you to Tran Huu Nhat Huy for his open source contributions in developing and training the Ego Lanes neural network.
🧩 Ego Lanes is developed within the Autoware Privately Owned Vehicle (PoV) Working Group, where we build and validate open source AI models for real-world autonomous driving — together with the global community.
💬 Interested in testing, contributing, or joining the PoV WG? Reach out — we’ll get you onboard.
🔜 More open source AI models are coming soon. Stay tuned.


