01 · Weekly · 2 slots
ADAS working group
Develops L2 driver assistance technologies with an end-to-end focus, and manages the Vision Pilot project.
One open stack — from raw sensor data to control commands — for every vehicle that needs to navigate autonomously.

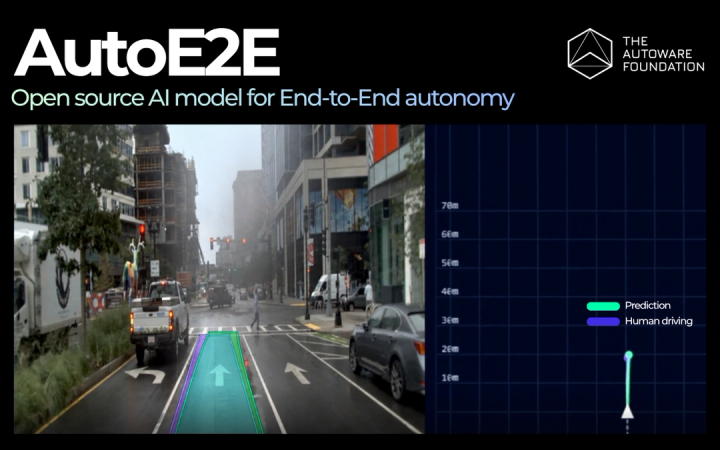
Neural networks map camera pixels directly to driving, learning the whole task from data instead of hand-written rules between perception and planning.
The classical architecture. Each stage is its own package with typed interfaces, so you can replace a detector and keep the planner.
Run end-to-end and modular components side by side. The learned path drives for performance, while the modular path provides interpretable checks and a fallback.
The Autoware Foundation is a non-profit that has stewarded Autoware since 2018. Its members, from carmakers to chip designers, build the reference architecture together, so no single vendor owns the stack your vehicle runs on.
| Annual fee | Strategic$100Kper year | Premium$50Kper year | Industry$10Kper year | Basic$2.5Kper year | Academic$2Kper year, or in-kind |
|---|---|---|---|---|---|
| Decision making committees | Voting seat | Voting seat | Observer seat | Observer seat | Observer seat |
| AWF Board of Directors | Voting seat | Observer seat | —Not included | —Not included | —Not included |
| Executive-level access | —Not included | —Not included | —Not included | ||
| Key account manager | —Not included | —Not included | |||
| Taskforce meetings | —Not included | —Not included | |||
| Networking & marketing platform | |||||
| Apply | Join → | Join → | Join → | Join → | Join → |
Open-source projects and non-profit organisations collaborate with the Foundation through joint in-kind contributions, with the same rights as Academic members.
Apply as a partner →Working groups are where Autoware gets built, and they are open to members and contributors. Times are shown in your time zone, your local time.
Develops L2 driver assistance technologies with an end-to-end focus, and manages the Vision Pilot project.
Performs safety analysis and testing of Autoware's core technologies.
Develops L2++ to L4 end-to-end and hybrid technologies, and is responsible for the AutoE2E project.
Develops containerization and deployment technologies through Autoware's Open AD Kit project.
Manages the Autoware code base, APIs and overall project structure, and is responsible for Autoware Core and Universe.
Developing a reference design for highway trucking.
Evaluates and proposes reference designs for various applications.
Creating a reference design for low-speed, geofenced autonomy applications.
The people guiding the Foundation's governance, technology and community.
Co-founder and Chairman of the Autoware Foundation, and founder and CEO of AutoCore.ai. Previously Director of 96Boards and a principal technical director at NVIDIA.
LinkedIn ↗Creator of Autoware and founder of TIER IV. He started Autoware as an academic project and remains closely involved through the University of Tokyo and TIER IV.
LinkedIn ↗Vice President and General Manager of the Digital High Performance Computing Business (SoC Division) at Renesas Electronics, based in Dallas, Texas. A leading figure in software-defined vehicles, ADAS and automotive AI architectures.
LinkedIn ↗President of TIER IV North America, leading business development across North America and Europe. Previously general manager of Intel’s automotive telematics business.
LinkedIn ↗Technology entrepreneur, roboticist and AI expert who has architected open-source AI models for scene perception and autonomous driving. Previously founder and CEO of Physical AI start-ups.
LinkedIn ↗Software architect at TIER IV who oversees the technical direction of Autoware and works to grow its community of contributors.
LinkedIn ↗Companies build commercial products on the open Autoware stack. Start from a reference design for your use case, or work with the community on something new.
Proven starting points that pair the Autoware stack with the vehicle, sensors and operating domain of each use case.
Driver assistance and automated driving for passenger cars, from hands-free highway features to full self-driving development.
Talk to us →Driverless ride-hailing on complex city streets, using the full perception, planning and control stack.
Talk to us →Shuttles, campus pods and city buses running on fixed routes and in dedicated zones.
Talk to us →Autonomy for construction sites, mining and agriculture, on unstructured terrain beside people and machinery.
Talk to us →Forklifts, tuggers and mobile robots moving goods through warehouses, yards and factories.
Talk to us →Bring us a custom project, a technology you need developed, or an integration challenge. We'll help you scope it and connect you with the right people across the Autoware community.
Adapt Autoware to your vehicle, sensors and operating domain.
Co-develop new capabilities, from perception models to safety tooling.
Bring Autoware onto your hardware, middleware and existing software.